Chenxi Han
Ph.D. student·Tsinghua University
Hi there! I’m Chenxi Han, a Ph.D. student at Tsinghua University. My research focuses on reinforcement learning, imitation learning, and manipulation models for humanoid robots. I am advised by Prof. Houde Liu at the Tsinghua AI & Robot Lab and co-founded ZERITH, where I work on motion control and robot learning. I aim to enable robots to perform tasks more accurately and quickly in real-world settings while continually learning and improving.
Publications
Selected papers on robot learning, design, and control.
- PDFProjectWatch demoarXiv
Overview
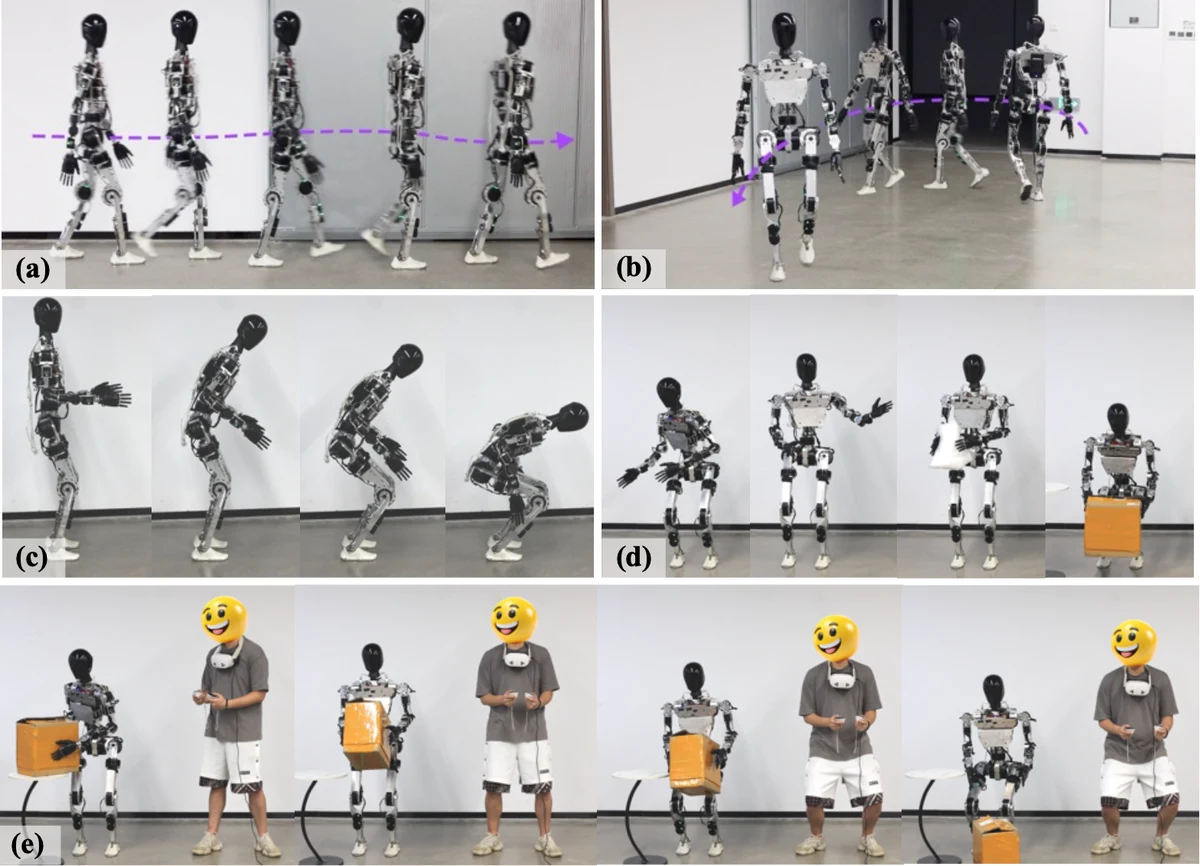
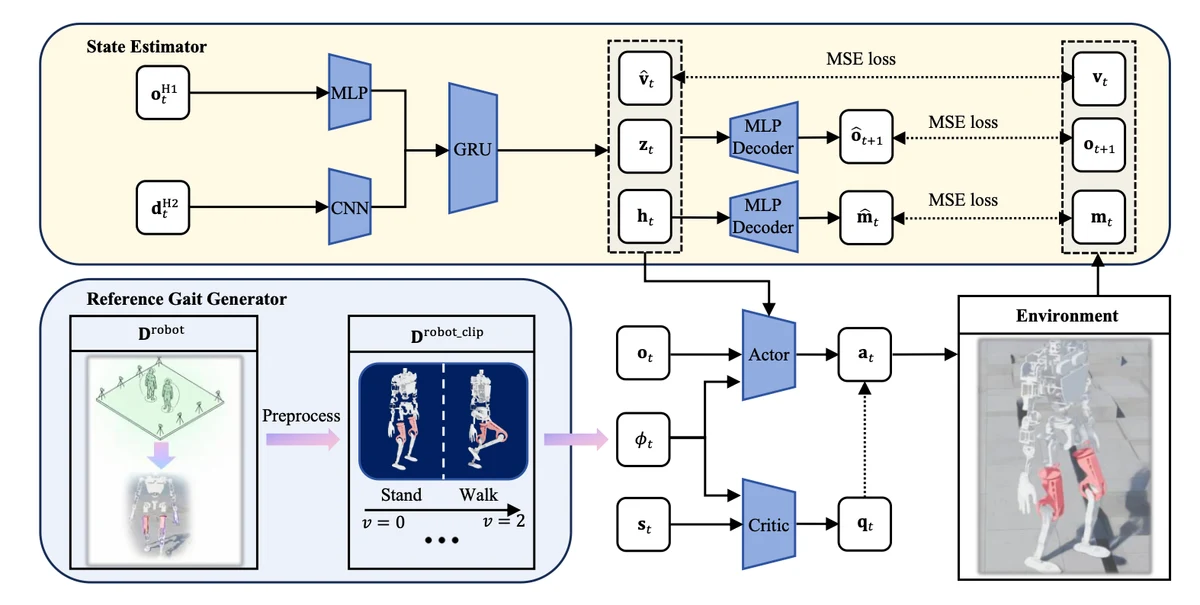
A compact motion generator that synthesizes human-like reference trajectories for imitation and reinforcement learning.
 PDF
Overview
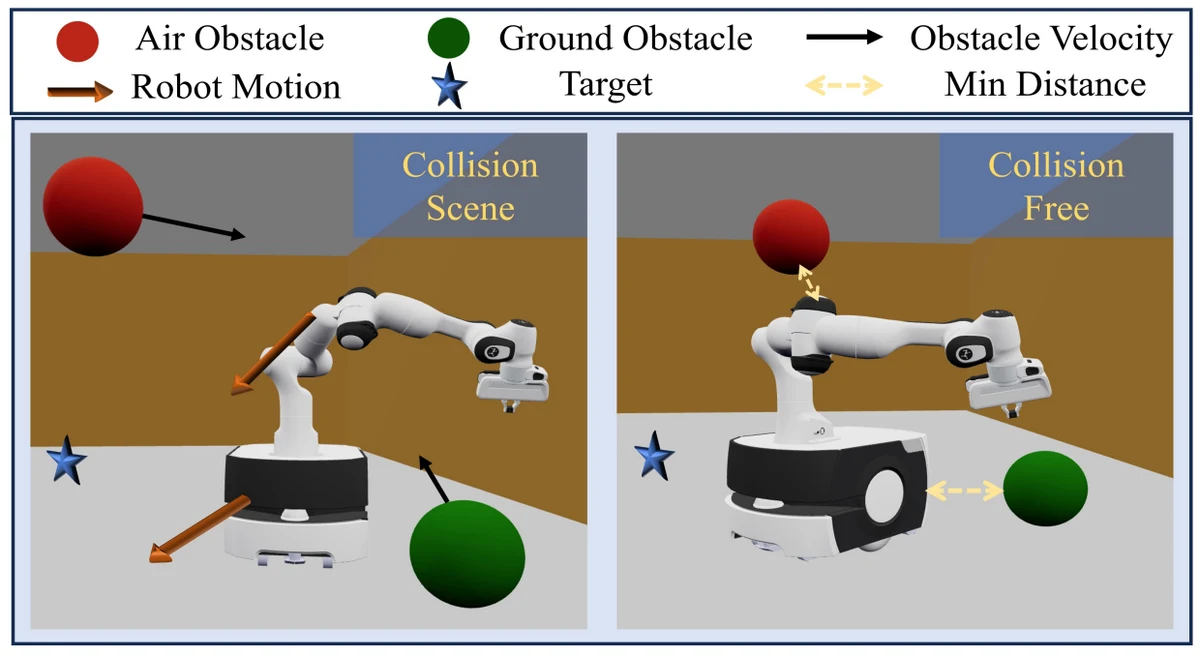
A CBF-QP whole-body controller for safe, real-time collision avoidance with mobile manipulators in dynamic environments.
- PDFProjectWatch demoarXiv
Overview
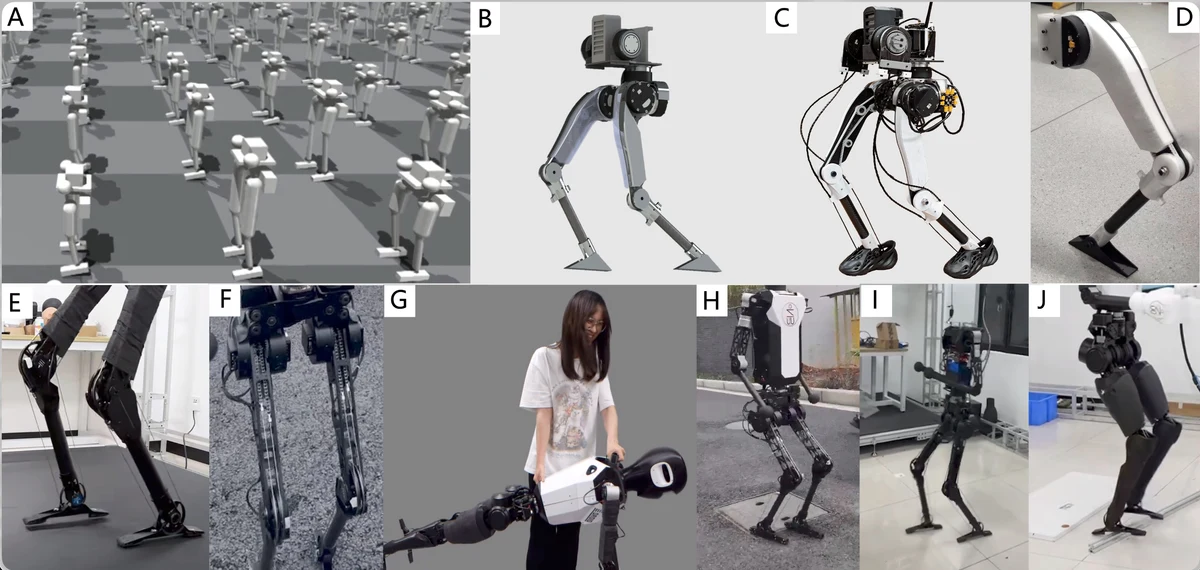
Reinforcement learning and evolutionary search for lightweight bipedal robot design and improved locomotion.
- PDFWatch demo
Overview
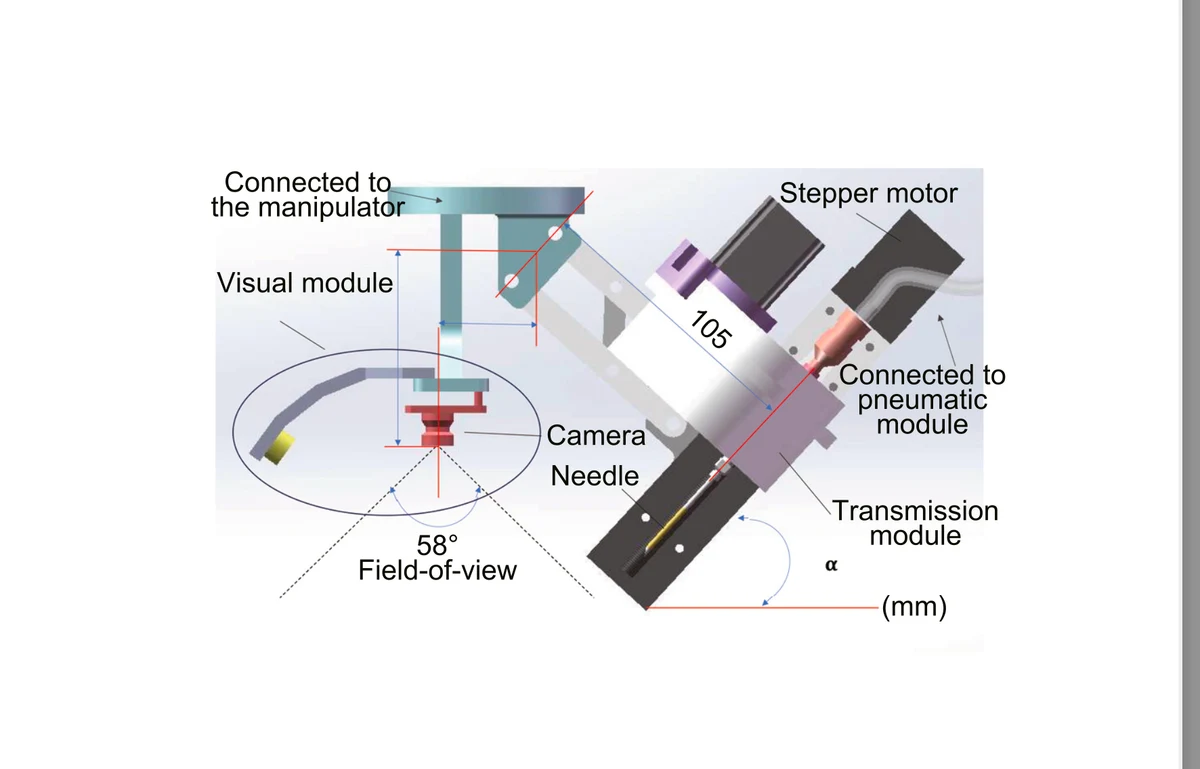
A pneumatic mechanism with visual feedback for precise, automated follicular unit extraction surgery.